

Contribution highlights:
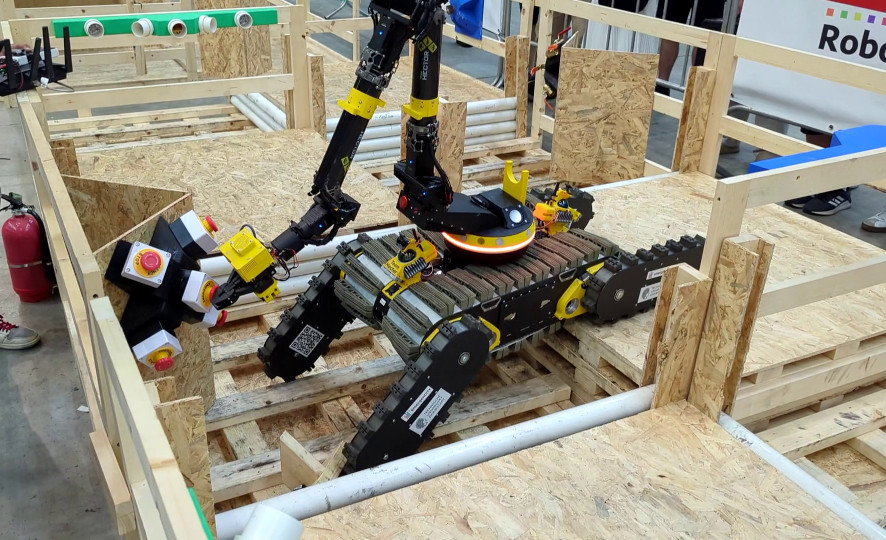
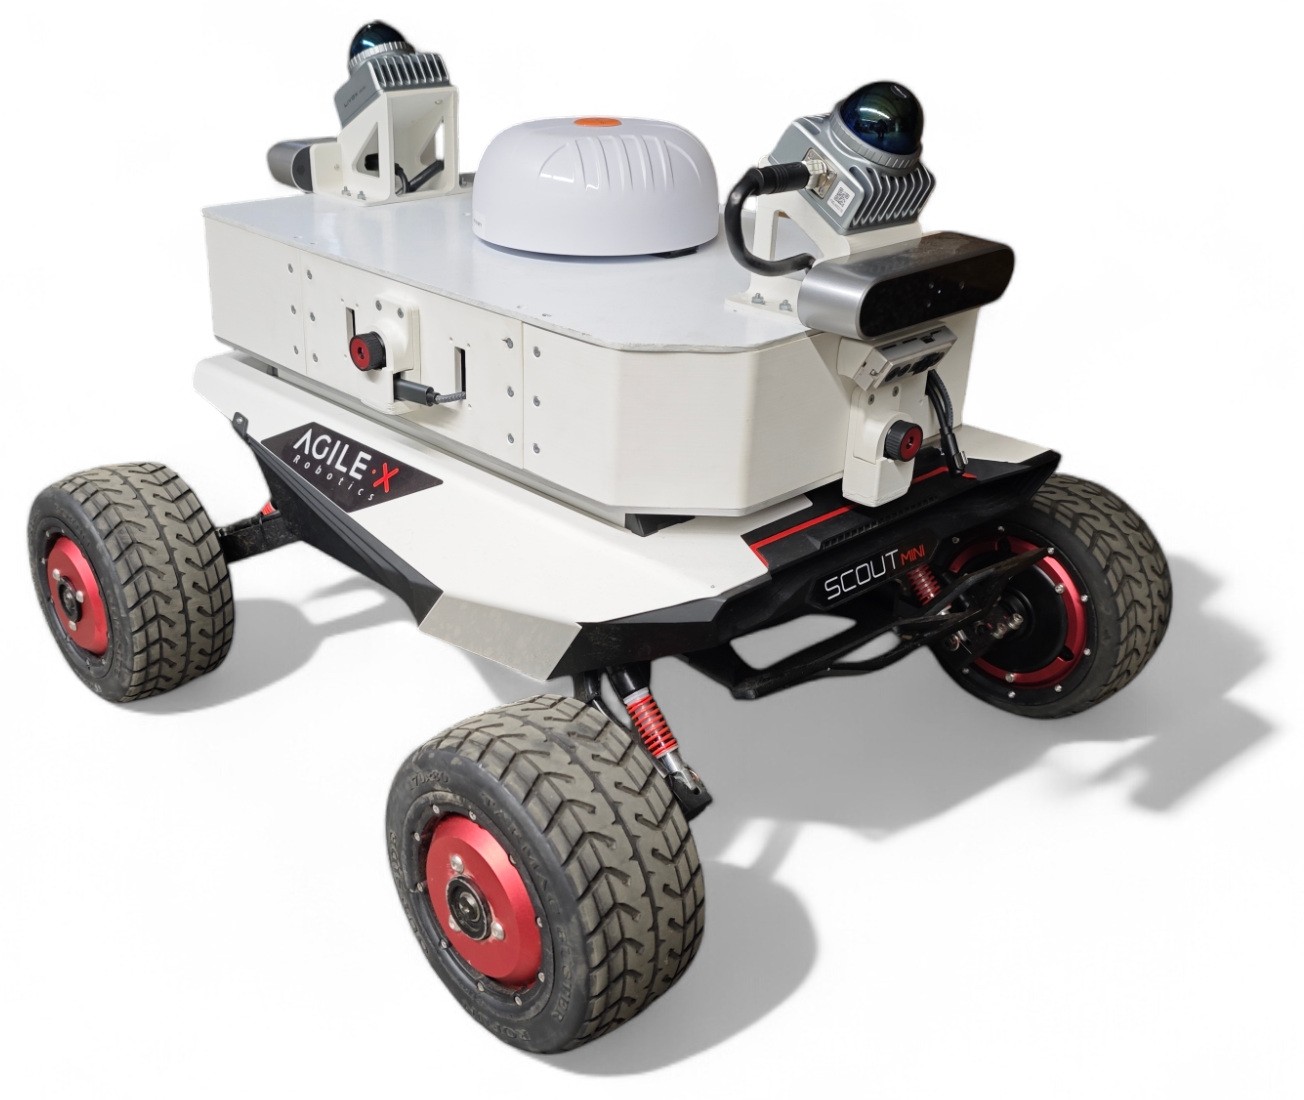
- Efficient robot pose prediction for navigation in unstructured terrain
- Operator-centric interface for rescue robot control and HRI research
- Bandwidth analysis and comparison of live streaming methods in degraded network conditions
- Extension of elevation maps to multi-story 3D environments